



Pinned Tweet
Is it possible to reconstruct 3D geometry from measurements of a miniature time-of-flight proximity sensor? Yes! I'm excited to share our CVPR 2024 paper, "Towards 3D Vision with Low-Cost Single-Photon Cameras"
🧵thread below

📜New paper: Recovering Parametric Scenes from Very Few Time-of-Flight Pixels. To appear at ICCV 2025.
We recover 3D parametric scenes (e.g. 6D object pose, human hand pose) from very few (8-15) distributed 3D pixels.
🧵thread below

ALT Teaser figure for the paper
This approach has applications anywhere that benefits from low-cost, lightweight sensing, like wearables, mobile devices, and robotics. We hope this work will inspire further development in this direction!
Project Page: cpsiff.github.io/recovering_…
ArXiv: arxiv.org/pdf/2509.16132
YouTube: youtu.be/p6G4_JU5y2k
Authors: Carter Sifferman*, Yiquan Li*, Yiming Li, Fangzhou Mu, Michael Gleicher, Mohit Gupta, Yin Li.


Carter Sifferman retweeted

📣 Excited to share a project I’ve been working on:
“Transientangelo: Few-Viewpoint Surface Reconstruction Using Single-Photon Lidar”
We render more accurate surfaces compared to prior baselines when trained on (2-5) input single-photon lidar views.
web: weihan1.github.io/transienta…

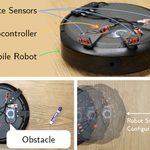
Excited to share our new paper, "Using a Distance Sensor to Detect Deviations in a Planar Surface", which was just accepted to RA-L (and will be presented at ICRA '25)
🌐Project page: cpsiff.github.io/using_a_dis…
📜arXiv: arxiv.org/pdf/2408.03838
🧵thread below 🧵
Looking forward to extending this work. There's a lot of potential for improvement when we design a sensing system starting from time-of-flight histograms rather than distance estimates.