
Building https://nitter.gq/t.co/mxfm66h1N2
Toronto
Joined December 2012
- Tweets702
- Following370
- Followers105
- Likes2.1K



Frans Ramirez retweeted

Lo único más poderoso que el odio, es el amor.
The Only Thing More Powerful Than Hate is Love. @sanbenito #AppleMusicHalftime

🚀 Launching a new blog series sharing actionable solutions from my dev projects! First up: Building Scalable Design Systems with TanStack Forms.
Struggling with custom form fields that play nicely with your component library?
Deep dive into creating custom fields using @TanStack_Forms + React. Check the full post + code snippets here: fransramirez.com/blog/tansta…
More content on #React patterns, #TypeScript, and more soon! 👨💻
49
#WealthsimpleCrypto #contest para cerrar año.

Want a chance to win 1 full bitcoin? Yeah, you do. Repost and reply with #WealthsimpleCrypto and #contest to be entered into our all-time highest giveaway.

64
Frans Ramirez retweeted

Not every foundation model needs to be gigantic. We trained a 1.5M-parameter neural network to control the body of a humanoid robot. It takes a lot of subconscious processing for us humans to walk, maintain balance, and maneuver our arms and legs into desired positions. We capture this “subconsciousness” in HOVER, a single model that learns how to coordinate the motors of a humanoid robot to support locomotion and manipulation.
We trained HOVER in NVIDIA Isaac, a GPU-powered simulation suite that accelerates physics by 10,000x faster than real time. To put the number in perspective, the robots undergo 1 year of intense training in a virtual “dojo”, but take only ~50 minutes of wall clock time on one GPU card. The neural net then transfers zero-shot to the real world without finetuning.
HOVER can be *prompted* for various types of high-level motion instructions that we call “control modes”. To name a few:
- Head and hand poses: can be captured by XR devices like Apple Vision Pro.
- Whole-body poses: via MoCap or RGB camera.
- Whole-body joint angles: Exoskeleton.
- Root velocity command: Joysticks.
What HOVER enables:
- A unified interface for us to control the robot using whichever input devices are convenient at hand.
- An easier way to collect whole-body teleoperation data for training.
- An upstream Vision-Language-Action model to provide motion instructions, which HOVER translates to low-level motor signals at high frequency.
HOVER supports any humanoid that can be simulated in Isaac. Bring your own robot, and watch it come to life!
It's a big teamwork from NVIDIA GEAR Lab and collaborators: 🧵
Are you having issues with lambda resource consumption for simple tasks? No worries, try cargo-lambda.info/ and stop worrying.
32
Here is a nice and friendly starting point for those interested in programming. Thanks to @TheOdinProject. theodinproject.com/
29
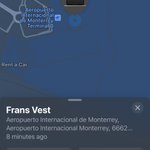
Hilo de como olvide una laptop en el avión y aún que puedo rastrearla nadie me puede ayudar a recuperarla.
@Aeromexico
Posteare donde anda mi laptop por México/mundo, aunque cada vez tengo menos esperanza de encontrarla :( . @Aeromexico @AMRewardsMx @AeromexicoUSA
2
86
A la hora correspondiente me hablan de Aeroméxico diciendo que realizaron la inspección y no se encontró nada. En ese momento yo la doy por perdida. Pero, hace un par de hora recibo una actualización de la laptop que ahora se encuentra en el aeropuerto de Monterrey.
2
76

