

Head of Mathematics and Computing Science, Sturgeon Comp High School Sponsor of Student Robotic Project: "To Recognize and Retrieve Biohazards Autonomously"
Sturgeon County, Alberta
Joined April 2017
- Tweets378
- Following48
- Followers35
- Likes29





Kevin Hubick retweeted

When Albert Einstein met Charlie Chaplin in 1931, Einstein said, "What I admire most about your art is its universality. You do not say a word, and yet the world understands you." "It's true." Replied Chaplin, "But your fame is even greater. The world admires you, when no one understands you."


Kevin Hubick retweeted

Bots have arrived and now we are just waiting for you! Tomorrow we'll be joined by thousands of students on over 450 FIRST Robotics Competition teams from all over the world. Watch the event action on FIRSTtv starting on April 21 at 8:30am CT: hubs.ly/Q018hW9S0
#FIRSTChamp

Perseverance and its predecessors Spirit and Opportunity have been, and continue to be, truly remarkable platforms for deep and enriched STEM based student learning providing wonderful examples for my students to explore and mimic #SturgeonRobotics

As I get ready to launch as part of the #ClassOf2020, I’m thinking back on all the exams & experiences I’ve been through. See what it takes to prepare an adventurer like me for a new world out there. Good luck to all persevering through tests of your own. go.nasa.gov/2WF29G0
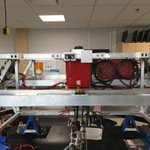
Just need to run some sensor cables and Eric can transfer his prototype work from the bench top to the rover. Really looking forward to having a lab full of students again 😃. The 360° rotational RP-LIDAR is temporarily placed on top for testing purposes. #SturgeonRobotics


I finished printing the last of the sensor assemblies and finally mounted everything. Being able to complete things over a couple of lunches is just one more testament to the amazing amount of work my students had completed prior to classes being cancelled. #SturgeonRobotics
Thought I'd share Lucas's first comment..., "looks like a spider with all those eyes." Most spiders have 8 eyes, the Spirit Rover has 24 (including the rotating RP-LIDAR laser sensor sitting on top). There's very little chance that our rover will miss anything close. #SpiritRover

I finished mounting the rover's fixed sensors. There are 17 short range HC-SR04 ultrasonic sensors and 5 long range narrow beam Garmin LIDAR-Lite v3 laser sensors distributed around the chassis plus an additional forward facing wide beam Omni PreSense OPS241-B radar sensor.


Definitely want to get my hands on one of these! Looking forward to evaluating its application in our autonomous rover's computer vision system #SturgeonRobotics #SpiritRover

Our new Raspberry Pi High Quality Camera alongside the Raspberry Pi 4.
Photo courtesy of the new Official Raspberry Pi Camera Guide, available from the Raspberry Pi Press online store: store.rpipress.cc/products/t…

3
Impeccable timing! We would like to enhance the scan accuracy in the rover's optical "computer vision" system to improve the object detection process. Currently using a 720P USB camera and the 8 megapixel Pi v2.1 camera but this update could be the solution we're looking for!
🚨 New Product 🚨 We’re pleased to announce a new member of the Raspberry Pi camera family: the 12.3-megapixel High Quality Camera, available today for just $50, alongside a range of interchangeable lenses starting at $15. raspberrypi.org/blog/new-pro…


While eating my sandwich at lunch, I worked on a few sensor assemblies. The corner mount for two (of the five) long range Garmin LIDAR-Lite v3 sensors provides an excellent base for sensors at 45° and 315° off axis.


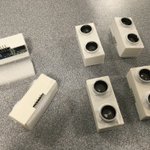
The last six ultra-sonic sensors and a LIDAR mount are now done (the extra piece is a 45° corner adapter). With the completed assemblies, I can mount all 17 ultrasonic sensors, the 5 LIDAR sensors and single radar sensor on to the chassis for the rover's proximal sensory array.


Connor had created a protective housing for the OPS-243B radar sensor before class cancellations due to COVID. Check this off the "to do" list as it's ready for mounting on the rover chassis.


Back in the lab and we've just finished our daily video staff meet. Really need to catch up on some marking when I'm not teaching today but hopefully can also run the last of the sensor assembly 3-D prints while I work! Here's a look at the protective housing for the LIDAR.

Eric asked us to create offset angles for sensors not mounted on the rover's axis or diagonal so I modified Connor's 3-D mount, tilting it to an angle of 22.5° (midway between 0° and 45°). Reflecting it horizontally creates the opposing angle, now to print four of each in total.

To make up for some lost time due to COVID closure, I'm running the final 3-D prints for the sensor assemblies and will mount them on the chassis. This way, it should be a relatively quick task for Eric to move his Raspberry Pi based prototype for the sensor array to the Rover.
Before classes were cancelled, Eric was working a plan using sensors (ultrasonic, LIDAR and radar) to provide proximal "awareness" to the rover. Here is his original concept and two follow-up plans.


Connor used some silicone caulk to seal the HC-SR04 sensors in the housings, I completed the prints for the sensor mounts and started attaching the completed weather resistant assemblies to the rover chassis.


First order of business to prepare for students to return is to finish the 3-D printing projects that Connor (graduating this spring) was mostly through. Connor had designed a protective housing and mount for the HC-SR04 ultrasonic sensors.


