

Physics/Robotics Engineer. Sim2Real of autonomous solutions for harsh environments. Member of @roboteverest mission and musician https://nitter.gq/t.co/XNFPFsWTU2
California, USA
Joined February 2024
- Tweets189
- Following265
- Followers191
- Likes455


Pinned Tweet
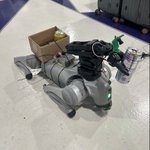
First look at the autonomous trash picking solution in action.
About its reachability, or "when you have to deal with the hardware at hand" :
- Added extended links to the arm for a longer reach while keeping a reasonable payload capacity
- Defined a reachability region for the arm around the quadruped
- Made the quadruped crouch when the target object is detected inside that region
PS: The camera cable stresses me out too - Moving to an onboard Raspberry Pi 5 setup.
With a quadruped Go2 @UnitreeRobotics from @nebiusai @DhruvDiddi and arm SO101 @LeRobotHF :)
Designed and 3D-printed what would be my dream pair of trail-running (and slightly fashionable) shoes for a Unitree G1 humanoid.
Ready to hit the trails now 🏔️
Printed in TPU 95A / Fake Salomon logo of course - just love the brand.
G1 from @cyberneticphysx


Chloe Pilon retweeted
Announcing the beta release of the Pi API. We’ve partnered with companies across diverse industries to adapt our models to their robots and applications, from harvesting strawberries to assembling servers. Now we’re opening access to more teams.


Chloe Pilon retweeted

We worked with @liangsu325045, the creator of FlashRT, to port FlashRT to @AMD GPUs (first CDNA4, then CDNA3)!
Along the way, we found that FP8 actually slows down π0.5’s decoder. So we wrote a custom BF16 path for CDNA3 instead.
35ms π0.5, 19.6ms GR00T.
What we learned 🧵👇
Allow me to reintroduce myself :
My name is Chloe, I’m a Physics Engineer from Montreal. While completing my engineering studies, I also had an entrepreneurial career in music : I released 7 albums (2M+ views online), played 75 shows, released more than 20 music videos and partnered with Red Bull Music, Quebecor or FrancosMTL.
During my holidays, I would go on solo cycling trip across India, Taiwan and the US (~10,000 km).
I then moved to Paris to work at a data center infrastructure company offering multiphysics simulation. One of my first mandates was to configure and deploy a modular datacenter for our first major client. I learned Mandarin to manage OEM/ODM relations in Taiwan. During this period, I also discovered ultra-trail running and completed 7 marathons and 23 half-marathons in one year.
But I felt everything was happening in California. So in January I came to SF, later started working as a Simulation Engineer in Robotics, and fell in love with it. I no longer work there, and here you will see me build, explore, simulate, and deploy.
Looking forward to exchanging on all those topics!

Bonjour 👋
First assembly of the quadruped + robotic arm, powered by the quadruped’s battery, for autonomous trash picking in various environments.
@nebiusai @DhruvDiddi


Affordable setup to power a standalone robotic arm from a mobile robot’s battery (here, a quadruped) using a DC-DC converter:

Looking for access to a Unitree Go2 Pro in San Francisco for short tests, if anyone has a lead. Thank you in advance :)
Mutant incoming
Thank you @DhruvDiddi and @nebiusai for the access to the Go2 for testing!

I wanted to find an idea where I could use mostly off-the-shelf hardware to deploy an autonomous system *asap*, in a relevant use case that matches my vertical expertise.
I worked at a research center in Mexico focused on environmental conservation, where beach cleanup is a daily problem. Hotels also spend $$$ on cleaning every day, since the waves keep bringing back debris from the ocean. And it's very interesting to simulate small particles with MPM in Isaac Sim/Newton.
But this use case goes beyond the tropical tourism industry. I've run countless races, marathons and ultramarathons over the last few years: litter (plastic bottles, gels) on the streets, or in the mountains where people can't easily reach it, is a real problem. We could also talk about music festivals and large venues. And simply, debris on city streets.
Good news: San Francisco has beaches, mountains, and urban areas. A good place to start testing :)
Video contains : GO2 EDU with SO-101 with extended arms, using a YOLO11n-seg model for can segmentation.