htr.gr (@gr_htr) header
htr.gr (@gr_htr) profile picture

We build robotic vehicles with focus on energy autonomy. We use our patented, high performance, all metal flexible wheels for lunar exploration rovers.

Europe
Joined May 2022
Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)Photo by htr.gr (@gr_htr)
We are excited to announce the successful completion of our CNC mill upgrade under the SURE5.0 framework! Thanks to @SUREproject, we modernized the system to reduce waste, optimize energy use and enhance workplace collaboration! Special thanks to CRIIF who made this possible!
1
1
98
Simple persistence
2
37
QUAD and THERON ...
1
4
2
100
Chatting after a day's work
2
30
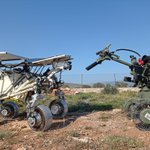
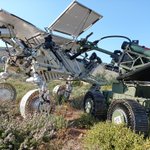
Patrolling robot THERON inspecting QUAD
3
31
Going up 22 degrees on a loose sand slope. The rover was stopped on the slope and started the motion with skid steering correction. Watch how the wheels helped the rover pull out.
6
Testing skid steering on loose sand
4
HTR wheels going up 40 degrees on loose slope with stones
3
We test our wheel-set for the new European Moon Rover. A scale model of the rover climbs off a ditch, half meter deep. Other videos will follow.
1
3
A unified 3D supervision environment supporting drone swarm and ground vehicles...
2
6
We scanned and reconstructed our 3km2 test site in 3D. Soon the QUAD will be moving in there too. Meanwhile, the platform can be used for drones.
3
Going down a 25 deg slope while steering can be tricky...
5
Another test setup uses loose soil and stones from recent excavation works. The active suspension adapts constantly to terrain irregularities. Notice how the rover approaches the slope sideways and climbs it.
3
6
HTR launches large scale test campaign of QUAD rover. Notice how QUAD is keeping horizontal when climbing the slope.
1
10
17