🤖PhD Student @OpenDriveLab|Robotics|Humanoids
Joined October 2024
- Tweets42
- Following234
- Followers121
- Likes133


Pinned Tweet
Humanoid robots have been prisoners of the lab. We set them free — with human data.
We present EgoHumanoid: The first endorsement of human-to-humanoid transfer for whole-body loco-manipulation.
🔗 Home: opendrivelab.com/EgoHumanoid
📑 Arxiv: arxiv.org/abs/2602.10106
🧵👇
Modi Shi retweeted

Anchor 1, Archon’s first humanoid controller for precise and stable whole-body manipulation.
- Sparse targets for flexible whole-body coordination
- Distribution shaping for stable behavior
- Decoupled feedback for precise control and flexible interfaces
- Systematic benchmarking of precision, stability, and reachability
Anchor 1 is a step toward Whole-Body Intelligence (WBI): giving intelligent robots the body control to reliably turn intent into action.
Key results:
- 30–80% reduction in tracking error
- More efficient real-world teleoperation data collection
- Higher success rates on autonomous manipulation tasks
Coming next: Expanded terrain capabilities, model weights, deployment code, and teleoperation tools targeted for release by the end of 2026.
🌐 Project & Early Access: archon.tech/research/anchor1
📄 Paper: arxiv.org/abs/2611.00193
Huge congrats to the Machenta team on the launch and all the outstanding work advancing in-context learning for robotics!

Today we’re out of stealth, and we’ve raised a $40m seed round co-led by @creandum and @usv, to bring Instant Robot Learning to life.
For the past few months, we‘ve been busy building a new company.
Machenta.
This follows results from a new kind of robot foundation model we’ve built, which I’m so excited to share with you today!
Usually, it takes hours/days of data collection and training to teach a robot.
We’ve built a model that learns tasks instantly: one demonstration, no further training.
A model trained entirely in simulation, without a single pixel of real-world data.
A model where teaching robots is so quick and easy, it feels like physical vibe coding.
A model for robots that learn like humans do, from someone like you.
Welcome to the era of Instant Robot Learning.
Thank you @Kathi_Wilhelm, @rebeccakaden, @hkanji, @jonno_evans and all of our angels for your support!
@Machenta_
Learn more: machenta.com/blog/instant-ro…
See below for what you can do with Instant Robot Learning!
1
7
463
Modi Shi retweeted

EgoExplorer (1/9)
🤖 Let's start with what EgoExplorer actually delivers.
📦 2,715 continuous recordings, 100+ hours and growing by ~5 hours every day, across 5 real environments: a chemistry lab, an industrial workspace, a study, a living room, and a food-prep area.
🧪 10 task templates with an emphasis on professional work.
Recovery episodes included: we record how people correct course, not just the clean path.
⏱️ Four synchronized streams on a shared 30 Hz grid (egocentric video, metric SMPL-X whole body, glove-measured fingers, 24×31 tactile per hand), with expert-checked step-level descriptions.
Teaching humanoids by doing what comes naturally to us 🤖
With SONIC, we achieve zero-shot transfer to G1 on a few simple whole-body tasks.
Only human demos for task post-training. No task-specific robot data.
A small step toward whole-body intelligence 👇

🧠 After Astra, I keep asking: what remains fundamentally hard in embodied AI?
My bet is on instinctive behaviors—the whole-body coordination that comes naturally to humans.
🤖 From human bodily intelligence to Whole-Body Intelligence (WBI).
Our exploration 👇
11
714
Modi Shi retweeted
🤖 Building Whole-Body Intelligence for the Real World. Were Just Getting Started.
From bending down to pick up objects and navigating steps to autonomously clearing tables, operating dishwashers, and organizing refrigerators, our robots are learning to perceive, move, manipulate, and coordinate their entire bodies in real-world environments.
Powered by our Whole-Body Intelligence (WBI) framework, were building generalist humanoid foundation models by combining large-scale human whole-body data pretraining, context-aware behavioral foundation models, and efficient post-training with real-robot data - turning human experience into real-world robotic skills.
👉 Watch Whole-Body Intelligence in action in our three-minute demo. More to come. Stay tuned at archon.tech
#ArchonRobotics #WholeBodyIntelligence #WBI #Humanoid #PhysicalAGI
Incredibly valuable industry insights!

Last week, we hosted Co-Founder and CEO of @Physical_int @hausman_k for an @sv_icons dinner.
Honestly, it felt like the moment we hosted Dario Amodei in 2022. Something big is happening, we all believe it is almost here, and it is not yet consensus. Physical AI seems like "that" thing.
@jakesaper described PI to us the week before as "Anthropic for the physical world," and after two hours with Karol I think that framing holds.
Here are a few insights from the dinner:
1. The data bottleneck is closing, and almost nobody has updated on this.
Karol's view is that we are quickly escaping robot data scarcity. Every serious lab now collects at scale internally, and on top of that there is a wave of data companies out of YC and elsewhere doing teleop and egocentric collection. The consequence worth sitting with: if you are building a company whose whole thesis is "we supply the data," you are entering the part of the stack that is getting solved and getting crowded at the same time.
2. The real bottleneck is the last 5%, and it comes from a misaligned objective.
This was the sharpest thing he said. These models are optimized to reproduce the actions in the dataset. What you actually care about is task success. Those two objectives diverge, so additional data on a given task stops moving you toward 100% reliability. Going from 0% to 20% to 60% zero-shot is a data story. Going from 60% to deployable is a reinforcement learning story. That is where PI is putting real effort, and he was open that nobody has cracked it.
The way they approach it: label large volumes of data with language and scores, train a generalized value function that can judge a trajectory in progress, then use that to score everything and improve the policy. The same way you can watch someone attempt a task and predict whether they will succeed.
3. Hardware reliability is the second bottleneck, and it surprised him.
Despite the enormous volume of robots coming out of China, he says there is still no platform robust enough for real deployment. Robots that stay up, stay safe around people, and survive daily use. This is a genuine gap, and it is a hardware company opportunity sitting in plain sight.
4. Cross-embodiment generalization works, and it's not fully clear why.
The same PI model runs on humanoids, single-arm and dual-arm manipulators, drones, cars, tractors, excavators, and surgical robots. Training across more embodiments makes the model better at any individual embodiment. Karol called this extremely counterintuitive and said plainly that they cannot fully explain it. Tractors and livestock robots somehow improve manipulation.
The limit: give it a brand new robot it has never seen, and it cannot look at the body and figure out how to move. It still needs a little data from that embodiment. He expects in-context adaptation eventually.
5. Generalists beat specialists, which is the worst startup advice ever given.
His words. Normal startup logic says own a narrow wedge, dominate it, then expand. If OpenAI had followed that, they would have started with translation only. What actually happened is that breadth of data distribution made the model better at every individual task, and he expects the same to hold for robotics. So when people ask him which vertical or which task PI will nail first, his answer is: many tasks at once, embrace diversity, and that is how you get good at any single one.
6. Simulation's near-term job is evaluation.
This reframed the sim debate for me. Evaluation does not scale: the better your model gets, the more real-world samples you need to tell whether the new one beats the old one. Thousands of physical rollouts is impractical. So sim's first real value is a closed-loop proxy that tells you if your model improved.
On sim for data, his diagnosis is specific: the blocker is asset creation. Rendering fidelity is fine. Locomotion works in sim because you only have to model your own robot accurately. Manipulation fails because you would have to model every object in the world you touch, including how it deforms, and there is no scalable way to do that. Real-world collection is faster and carries no distribution shift.
7. Tactile sensing is overrated as a blocker.
He has worked with tactile sensors a lot and has been disappointed by how little lift they give relative to the integration pain. PI's workaround is elegant: put a camera on the gripper, read the deformation of the gripper, and infer applied force. Now it is just another vision signal the model already knows how to consume. Tactile data is also awkward because you only get signal when you are touching something, so most of the time it is empty.
8. The VLA versus world model debate is blown out of proportion.
Companies are building their entire identity on an architectural choice you can swap in about three days. His view: data, data quality, diversity, and deployment matter far more at this stage. Worth remembering when you are diligencing robotics companies that pitch architecture as a moat.
9. Compute will be split, and inference is leaving the robot.
Models are already too large to sit entirely on the robot. The likely shape: a system-one policy on the edge handling low-level action and reflexes, and a system-two reasoner in the cloud, possibly parts of the same network. Where connectivity is bad, local inference boxes on site. Robot-specific silicon is further out, though every chip company wants it.
10. Why they chose the intelligence layer.
Every robotics company historically started with a robot they wanted to build. Everything else became subordinate to that, so the AI team stayed small and the intelligence was always the lopsided part. PI inverted it: solving physical intelligence is priority one, and hardware and software choices serve it. He had never seen a company organized this way, which is exactly why he thought it might work.
On the operating system analogy people keep reaching for: he pushed back. Operating systems work because they abstract the hardware away, and that abstraction breaks for robots, because all the complexity lives in the physical body and how it touches the world. The right abstraction sits higher, at the intelligence level, where you specify a command and any robot executes it.
11. What he would actually tell builders to work on.
Two things. Actuators in the West, because if Chinese actuators get restricted we have no domestic answer, and the supply chain problem goes deeper than most people check: rare earth refining, magnets, copper for coils, batteries, and the manufacturing know-how itself. And deployment: understanding ROI, integrating into a workflow, remote intervention, knowing when the robot should ask for help. His heuristic on where to build was blunt and worth writing down: if it is easy, it is probably the wrong place to enter, because it likely works worse than you think and everyone else is already there.
He also made the point that deployment companies end up owning the best data by accident, which everyone else will want.
12. The barrier to entry has genuinely collapsed.
Download an open model, fine-tune on a little data, get signs of life. One deployment company they work with had robots in a logistics setting three months in. That used to take five to seven years. Hardware is cheaper and intelligence is now available, which is why he thinks this is the best moment in history to start a robotics company.
13. There will be no ChatGPT moment.
He thinks it goes the way of Waymo. There was never a single Waymo moment, and then suddenly they were everywhere. Robots will show up in businesses, then industrial settings, then around people, then simple home applications, and at some point you look up and it happened.
14. First deployment will be shaped by tasks, and tasks cut across verticals.
The framework of picking a vertical may be wrong. His example: one of the tasks PI has focused on is assembling packaging boxes at a chocolate factory. You would file that under logistics, and it sits inside food. The same simple, low-variability tasks recur across industries that look unrelated. Start there, then expand into longer-horizon tasks, more human collaboration, mobility, and higher-consequence failures.
15. The home is the last problem, and privacy is a real part of it.
No two homes are alike, the task variety is enormous, and repeatability is low, so ROI per task is weak. You fold laundry twice a week. A home robot has to do many things to justify existing. On top of that: teleoperation means a stranger walking around your house, and even without teleop there is a robot collecting data in your home. He said outright that people underweight this today, and expects early adopters to opt in the way they did with Alexa.
16. On culture: run the experiment.
Most startups run on the conviction of the founder. Karol said PI would be bottlenecked by his ideas if they operated that way. What they kept from academia is the discipline of running the experiment, looking at the evidence without bias, and doubling down on what worked regardless of what you wanted to be true. His read on the history of robot learning is that most missteps happened because the honest path was hard and people believed the easier story.
17. On his own path: someone gave him a chance at every stage.
He knocked on a lab door in Munich as a student who did not know C, did not know Linux, and did not know robots. They gave him a shot anyway. Later, a visiting postdoc told him his two years of PhD work was worthless and he should be doing deep learning. He ignored him, went to his lecture that afternoon, and dropped everything the next day. That person is Sergey Levine, his co-founder. When someone asked what drives him, he credited the people who kept giving him chances.
18. Moats.
Earn the right to have one by making it work first. The moat appears naturally, because the problem is so hard.
Thanks, Karol, for the amazing evening with Icons.
Thanks to @AlmaImmigration for supporting Icons.

148
Modi Shi retweeted
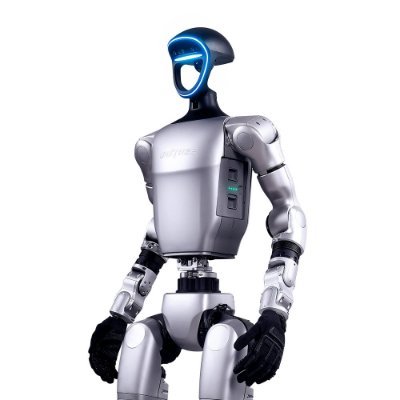
Unitree New Robot Preview: “Superman” Breaking the Limits of Humanity🥳
Standing high jump 2 m, top speed 12.66 m/s (0.85 m leg length)
Surpassing the standing high jump and running speed records of all humans around the world
This new machine has only been in development for a little over three months, with significant room for further improvement in the coming months.
Modi Shi retweeted

How can roboticists scale human manipulation data in the wild? EgoHumanoid builds a comprehensive pipeline which unlocks mobile manipulation training for robots — meaning that you can walk around and collect data for your robot anywhere you go. There are two key components to their recipe: view alignment, to reduce mismatch between human and robot camera views, and action alignment, to make sure human actions can be converted into robot actions. This makes it easier than ever to train robot policies and deploy them in previously-unseen environments. @idomihs joins us to tell us the details.
Watch Episode #96 of RoboPapers with @micoolcho and @DJiafei today!
Congrats on the launch! Excited to see The Lab accelerate robotics innovation 🚀

The Lab opens soon. When it does, we accelerate robotics R&D together.
Get in early, start contributing, and earn Bolts from day one.
app.bitrobot.ai
2
146
Had a great chat with @micoolcho and @DJiafei about EgoHumanoid and our journey toward leveraging robot-free egocentric human data for in-the-wild loco-manipulation. Thanks for having me!

Full episode dropping soon!
Geeking out with @idomihs on EgoHumanoid: Unlocking In-the-Wild Loco-Manipulation with Robot-Free Egocentric Demonstration opendrivelab.com/EgoHumanoid…
Co-hosted by @micoolcho @DJiafei
Thanks @DominiqueCAPaul for the great summary! One key insight from our paper: inconsistent speeds for similar observations hurt robot learning. A clean, consistent speed distribution—while preserving useful spatial diversity—makes imitation learning easier.
More details in our paper: ieeexplore.ieee.org/document…

If you're wondering how to get more performance out of less data in robot learning, then this new paper offers some useful pieces of advice.
1/ Above all, maximise scene diversity (we saw results with this in our actuator unboxing task)
2/ Maximise task diversity
3/ Maintain a similar speed for subtasks. Inconsistent speeds for the same observation make the data harder to fit.
Already collected your data?
You can "debias" it with their method. The key idea is that a small model learns the expected speed from the camera input and interpolates to a consistent speed.
I'm gonna try the debiasing method for our data and share whether it replicates for us.

2
234


Really useful when you want to collect data in a narrow house

Sydney, let's gather 🌇 Drinks, harbour views, and great conversations on embodied AI — come through!

Sydney, come sundown. 🌃
OpenDriveLab x @archon_robotics are throwing an afterparty!
TopTalents for Embodied AI, a social mixer at W Sydney, harbour views, golden hour, and the people building the next gen of Embodied Intelligence.
📅 Jul 14 · 7–10PM
📍 W Sydney
🎟️ Apply: luma.com/0ml7kuwb
#RSS2026 #EmbodiedAI #Sydney #WorldModel #FoundationModel

126
now that's real dexterity

Super excited to visit @wuji_global who's pushing the frontier with their advanced dexterous robotic hand
Most traditional robotic hands still rely on tendons/cables, but Wuji Hand uses direct-drive actuators embedded right in the fingers with worm gears. This solves the usual tendon problems by delivering smoother, more precise, and reliable motion with way less sim-to-real gap
It also has high dexterity with 20 active degrees of freedom and the weight/size feel almost exactly like an adult human hand
Got to test the newly launched Wuji Hand 2 today and was super fascinated! (watch how I handle the hand in the first video😂)

158
Modi Shi retweeted
Full episode dropping soon!
Geeking out with @jiazhi_yang2024 on RISE: Self-Improving Robot Policy with Compositional World Model opendrivelab.com/rise/
Co-hosted by @chris_j_paxton @DJiafei
Modi Shi retweeted

The ⚽️ #WorldCup2026 kicks off tonight 🏆 — and we're sending a humanoid onto the pitch too!
Meet RoboNaldo: a versatile humanoid football shooter.
It can strike the ball up to 13m/s, accurately lands within 17 cm of a 3 m target away, outdoors on real grass pitch, off a live human pass, with fully onboard perception.
opendrivelab.com/RoboNaldo
🧵👇
Modi Shi retweeted

🪜 What if humanoids could climb ladders and work on them straight out of simulation?
Meet LadderMan: a perceptive system for zero-shot sim-to-real ladder climbing and on-ladder manipulation.
Watch the humanoid climb, stabilize, and manipulate—all in one system. 🤖👇